YARP
Yet Another Robot Platform
 
Loading...
Searching...
No Matches
yarp::sig::Pose6D Class Reference

#include <idl_generated_code/yarp/sig/Pose6D.h>

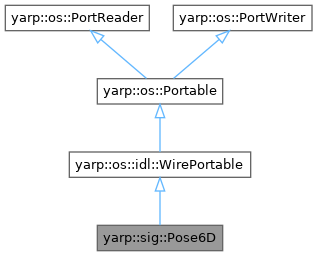
+ Inheritance diagram for yarp::sig::Pose6D:

Public Types

typedef yarp::os::idl::Unwrapped< Pose6D > unwrapped
 

Public Member Functions

 Pose6D ()=default
 
 Pose6D (const double x, const double y, const double z, const double roll, const double pitch, const double yaw)
 
bool read (yarp::os::idl::WireReader &reader) override
 
bool read (yarp::os::ConnectionReader &connection) override
 Read this object from a network connection.
 
bool write (const yarp::os::idl::WireWriter &writer) const override
 
bool write (yarp::os::ConnectionWriter &connection) const override
 Write this object to a network connection.
 
std::string toString () const
 
- Public Member Functions inherited from yarp::os::idl::WirePortable
virtual bool readBare (yarp::os::ConnectionReader &reader)
 
virtual bool writeBare (yarp::os::ConnectionWriter &writer) const
 
virtual bool readBottle (yarp::os::ConnectionReader &reader)
 
virtual bool writeBottle (yarp::os::ConnectionWriter &writer) const
 
- Public Member Functions inherited from yarp::os::Portable
virtual Type getType () const
 
- Public Member Functions inherited from yarp::os::PortReader
virtual ~PortReader ()
 Destructor.
 
virtual Type getReadType () const
 
- Public Member Functions inherited from yarp::os::PortWriter
virtual ~PortWriter ()
 Destructor.
 
virtual void onCompletion () const
 This is called when the port has finished all writing operations.
 
virtual void onCommencement () const
 This is called when the port is about to begin writing operations.
 
virtual yarp::os::Type getWriteType () const
 

Public Attributes

double x {0.0}
 
double y {0.0}
 
double z {0.0}
 
double roll {0.0}
 
double pitch {0.0}
 
double yaw {0.0}
 

Additional Inherited Members

- Static Public Member Functions inherited from yarp::os::Portable
static bool copyPortable (const PortWriter &writer, PortReader &reader)
 Copy one portable to another, via writing and reading.
 

Detailed Description

Definition at line 21 of file Pose6D.h.

Member Typedef Documentation

◆ unwrapped

Constructor & Destructor Documentation

◆ Pose6D() [1/2]

yarp::sig::Pose6D::Pose6D ( )
default

◆ Pose6D() [2/2]

yarp::sig::Pose6D::Pose6D ( const double  x,
const double  y,
const double  z,
const double  roll,
const double  pitch,
const double  yaw 
)

Definition at line 16 of file Pose6D.cpp.

Member Function Documentation

◆ read() [1/2]

bool yarp::sig::Pose6D::read ( yarp::os::ConnectionReader &  reader)
overridevirtual

Read this object from a network connection.

Override this for your particular class.

Parameters
readeran interface to the network connection for reading
Returns
true iff the object is successfully read

Implements yarp::os::Portable.

Definition at line 60 of file Pose6D.cpp.

◆ read() [2/2]

bool yarp::sig::Pose6D::read ( yarp::os::idl::WireReader &  reader)
overridevirtual

Reimplemented from yarp::os::idl::WirePortable.

Definition at line 33 of file Pose6D.cpp.

◆ toString()

std::string yarp::sig::Pose6D::toString ( ) const

Definition at line 113 of file Pose6D.cpp.

◆ write() [1/2]

bool yarp::sig::Pose6D::write ( const yarp::os::idl::WireWriter &  writer) const
overridevirtual

Reimplemented from yarp::os::idl::WirePortable.

Definition at line 73 of file Pose6D.cpp.

◆ write() [2/2]

bool yarp::sig::Pose6D::write ( yarp::os::ConnectionWriter &  writer) const
overridevirtual

Write this object to a network connection.

Override this for your particular class. Be aware that depending on the nature of the connections a port has, and what protocol they use, and how efficient the YARP implementation is, this method may be called once, twice, or many times, as the result of a single call to Port::write

Parameters
writeran interface to the network connection for writing
Returns
true iff the object is successfully written

Implements yarp::os::Portable.

Definition at line 100 of file Pose6D.cpp.

Member Data Documentation

◆ pitch

double yarp::sig::Pose6D::pitch {0.0}

Definition at line 30 of file Pose6D.h.

◆ roll

double yarp::sig::Pose6D::roll {0.0}

Definition at line 29 of file Pose6D.h.

◆ x

double yarp::sig::Pose6D::x {0.0}

Definition at line 26 of file Pose6D.h.

◆ y

double yarp::sig::Pose6D::y {0.0}

Definition at line 27 of file Pose6D.h.

◆ yaw

double yarp::sig::Pose6D::yaw {0.0}

Definition at line 31 of file Pose6D.h.

◆ z

double yarp::sig::Pose6D::z {0.0}

Definition at line 28 of file Pose6D.h.


The documentation for this class was generated from the following files: