Definition at line 250 of file ISimulatedWorldMsgs.cpp.
◆ funcptr_t
◆ ISimulatedWorldMsgs_makeCylinder_helper() [1/2]
| ISimulatedWorldMsgs_makeCylinder_helper::ISimulatedWorldMsgs_makeCylinder_helper |
( |
| ) |
|
|
default |
◆ ISimulatedWorldMsgs_makeCylinder_helper() [2/2]
| ISimulatedWorldMsgs_makeCylinder_helper::ISimulatedWorldMsgs_makeCylinder_helper |
( |
const std::string & |
id_name, |
|
|
const double |
radius, |
|
|
const double |
length, |
|
|
const yarp::sig::Pose6D & |
pose, |
|
|
const yarp::sig::ColorRGB & |
color, |
|
|
const std::string & |
frame_name, |
|
|
const bool |
gravity_enable, |
|
|
const bool |
collision_enable |
|
) |
| |
◆ call()
◆ read()
Read this object from a network connection.
Override this for your particular class.
- Parameters
-
| reader | an interface to the network connection for reading |
- Returns
- true iff the object is successfully read
Implements yarp::os::Portable.
Definition at line 1688 of file ISimulatedWorldMsgs.cpp.
◆ write()
Write this object to a network connection.
Override this for your particular class. Be aware that depending on the nature of the connections a port has, and what protocol they use, and how efficient the YARP implementation is, this method may be called once, twice, or many times, as the result of a single call to Port::write
- Parameters
-
| writer | an interface to the network connection for writing |
- Returns
- true iff the object is successfully written
Implements yarp::os::Portable.
Definition at line 1683 of file ISimulatedWorldMsgs.cpp.
◆ cmd
| Command ISimulatedWorldMsgs_makeCylinder_helper::cmd |
◆ reply
| Reply ISimulatedWorldMsgs_makeCylinder_helper::reply |
◆ s_cmd_len
| constexpr size_t ISimulatedWorldMsgs_makeCylinder_helper::s_cmd_len {9} |
|
staticconstexpr |
◆ s_help
| constexpr const char* ISimulatedWorldMsgs_makeCylinder_helper::s_help {""} |
|
staticconstexpr |
◆ s_prototype
| constexpr const char* ISimulatedWorldMsgs_makeCylinder_helper::s_prototype {"yarp::dev::ReturnValue ISimulatedWorldMsgs::makeCylinder(const std::string& id_name, const double radius, const double length, const yarp::sig::Pose6D& pose, const yarp::sig::ColorRGB& color, const std::string& frame_name, const bool gravity_enable, const bool collision_enable)"} |
|
staticconstexpr |
◆ s_reply_len
| constexpr size_t ISimulatedWorldMsgs_makeCylinder_helper::s_reply_len {1} |
|
staticconstexpr |
◆ s_tag
| constexpr const char* ISimulatedWorldMsgs_makeCylinder_helper::s_tag {"makeCylinder"} |
|
staticconstexpr |
◆ s_tag_len
| constexpr size_t ISimulatedWorldMsgs_makeCylinder_helper::s_tag_len {1} |
|
staticconstexpr |
The documentation for this class was generated from the following file:


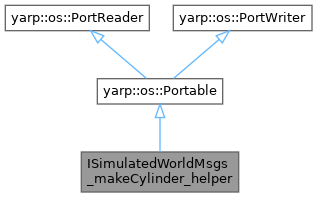
 Inheritance diagram for ISimulatedWorldMsgs_makeCylinder_helper:
 1.9.8