|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
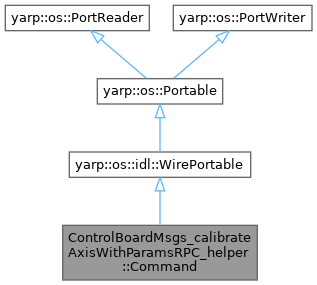
 Inheritance diagram for ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command:
Public Member Functions | |
| Command ()=default | |
| Command (const std::int32_t j, const std::int32_t ui, const double v1, const double v2, const double v3) | |
| ~Command () override=default | |
| bool | write (yarp::os::ConnectionWriter &connection) const override |
| Write this object to a network connection. | |
| bool | read (yarp::os::ConnectionReader &connection) override |
| Read this object from a network connection. | |
| bool | write (const yarp::os::idl::WireWriter &writer) const override |
| bool | writeTag (const yarp::os::idl::WireWriter &writer) const |
| bool | writeArgs (const yarp::os::idl::WireWriter &writer) const |
| bool | read (yarp::os::idl::WireReader &reader) override |
| bool | readTag (yarp::os::idl::WireReader &reader) |
| bool | readArgs (yarp::os::idl::WireReader &reader) |
| Public Member Functions inherited from yarp::os::idl::WirePortable | |
| virtual bool | readBare (yarp::os::ConnectionReader &reader) |
| virtual bool | writeBare (yarp::os::ConnectionWriter &writer) const |
| virtual bool | readBottle (yarp::os::ConnectionReader &reader) |
| virtual bool | writeBottle (yarp::os::ConnectionWriter &writer) const |
| Public Member Functions inherited from yarp::os::Portable | |
| virtual Type | getType () const |
| Public Member Functions inherited from yarp::os::PortReader | |
| virtual | ~PortReader () |
| Destructor. | |
| virtual Type | getReadType () const |
| Public Member Functions inherited from yarp::os::PortWriter | |
| virtual | ~PortWriter () |
| Destructor. | |
| virtual void | onCompletion () const |
| This is called when the port has finished all writing operations. | |
| virtual void | onCommencement () const |
| This is called when the port is about to begin writing operations. | |
| virtual yarp::os::Type | getWriteType () const |
Public Attributes | |
| std::int32_t | j {0} |
| std::int32_t | ui {0} |
| double | v1 {0.0} |
| double | v2 {0.0} |
| double | v3 {0.0} |
Additional Inherited Members | |
| Static Public Member Functions inherited from yarp::os::Portable | |
| static bool | copyPortable (const PortWriter &writer, PortReader &reader) |
| Copy one portable to another, via writing and reading. | |
Definition at line 6155 of file ControlBoardMsgs.cpp.
|
default |
| ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::Command | ( | const std::int32_t | j, |
| const std::int32_t | ui, | ||
| const double | v1, | ||
| const double | v2, | ||
| const double | v3 | ||
| ) |
Definition at line 27213 of file ControlBoardMsgs.cpp.
|
overridedefault |
|
overridevirtual |
Read this object from a network connection.
Override this for your particular class.
| reader | an interface to the network connection for reading |
Implements yarp::os::Portable.
Definition at line 27231 of file ControlBoardMsgs.cpp.
|
overridevirtual |
Reimplemented from yarp::os::idl::WirePortable.
Definition at line 27280 of file ControlBoardMsgs.cpp.
| bool ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::readArgs | ( | yarp::os::idl::WireReader & | reader | ) |
Definition at line 27304 of file ControlBoardMsgs.cpp.
| bool ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::readTag | ( | yarp::os::idl::WireReader & | reader | ) |
Definition at line 27291 of file ControlBoardMsgs.cpp.
|
overridevirtual |
Reimplemented from yarp::os::idl::WirePortable.
Definition at line 27241 of file ControlBoardMsgs.cpp.
|
overridevirtual |
Write this object to a network connection.
Override this for your particular class. Be aware that depending on the nature of the connections a port has, and what protocol they use, and how efficient the YARP implementation is, this method may be called once, twice, or many times, as the result of a single call to Port::write
| writer | an interface to the network connection for writing |
Implements yarp::os::Portable.
Definition at line 27222 of file ControlBoardMsgs.cpp.
| bool ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::writeArgs | ( | const yarp::os::idl::WireWriter & | writer | ) | const |
Definition at line 27260 of file ControlBoardMsgs.cpp.
| bool ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::writeTag | ( | const yarp::os::idl::WireWriter & | writer | ) | const |
Definition at line 27252 of file ControlBoardMsgs.cpp.
| std::int32_t ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::j {0} |
Definition at line 6175 of file ControlBoardMsgs.cpp.
| std::int32_t ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::ui {0} |
Definition at line 6176 of file ControlBoardMsgs.cpp.
| double ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::v1 {0.0} |
Definition at line 6177 of file ControlBoardMsgs.cpp.
| double ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::v2 {0.0} |
Definition at line 6178 of file ControlBoardMsgs.cpp.
| double ControlBoardMsgs_calibrateAxisWithParamsRPC_helper::Command::v3 {0.0} |
Definition at line 6179 of file ControlBoardMsgs.cpp.
 1.9.8