YARP
Yet Another Robot Platform
 
Loading...
Searching...
No Matches
ISimulatedWorldMsgsImpl Class Reference

#include <networkWrappers/simulatedWorld_nws_yarp/SimulatedWorld_nws_yarp.h>

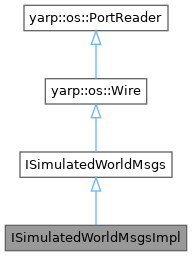
+ Inheritance diagram for ISimulatedWorldMsgsImpl:

Public Member Functions

yarp::dev::ReturnValue makeSphere (const std::string &id_name, const double radius, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) override
 
yarp::dev::ReturnValue makeBox (const std::string &id_name, const double width, const double height, const double thickness, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) override
 
yarp::dev::ReturnValue makeCylinder (const std::string &id_name, const double radius, const double length, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) override
 
yarp::dev::ReturnValue makeFrame (const std::string &id_name, const double size, const yarp::sig::Pose6D &pose, const yarp::sig::ColorRGB &color, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) override
 
yarp::dev::ReturnValue makeModel (const std::string &id_name, const std::string &filename, const yarp::sig::Pose6D &pose, const std::string &frame_name, const bool gravity_enable, const bool collision_enable) override
 
yarp::dev::ReturnValue makeActor (const std::string &id_name, const std::string &skin_filename, const std::string &actor_filename, const yarp::sig::Pose6D &pose) override
 
yarp::dev::ReturnValue changeColor (const std::string &id, const yarp::sig::ColorRGB &color) override
 
yarp::dev::ReturnValue setPose (const std::string &id, const yarp::sig::Pose6D &pose, const std::string &frame_name="") override
 
yarp::dev::ReturnValue enableGravity (const std::string &id, const bool enable) override
 
yarp::dev::ReturnValue enableCollision (const std::string &id, const bool enable) override
 
getPoseReturnValue getPose (const std::string &id, const std::string &frame_name) override
 
yarp::dev::ReturnValue deleteObject (const std::string &id) override
 
yarp::dev::ReturnValue deleteAll () override
 
getListReturnValue getList () override
 
yarp::dev::ReturnValue attach (const std::string &id, const std::string &link_name) override
 
yarp::dev::ReturnValue detach (const std::string &id) override
 
yarp::dev::ReturnValue rename (const std::string &old_name, const std::string &new_name) override
 
 ISimulatedWorldMsgsImpl (yarp::dev::ISimulatedWorld *iSim)
 
 ~ISimulatedWorldMsgsImpl ()=default
 
std::mutex * getMutex ()
 
- Public Member Functions inherited from ISimulatedWorldMsgs
virtual yarp::os::ApplicationNetworkProtocolVersion getLocalProtocolVersion ()
 
virtual yarp::os::ApplicationNetworkProtocolVersion getRemoteProtocolVersion ()
 
virtual bool checkProtocolVersion ()
 
 ISimulatedWorldMsgs ()
 
virtual std::vector< std::string > help (const std::string &functionName="--all")
 
bool read (yarp::os::ConnectionReader &connection) override
 Read this object from a network connection.
 
- Public Member Functions inherited from yarp::os::Wire
yarp::os::WireLink & yarp ()
 Get YARP state associated with this object.
 
const yarp::os::WireLink & yarp () const
 Get YARP state associated with this object (const version).
 
- Public Member Functions inherited from yarp::os::PortReader
virtual ~PortReader ()
 Destructor.
 
virtual Type getReadType () const
 

Detailed Description

Definition at line 33 of file SimulatedWorld_nws_yarp.h.

Constructor & Destructor Documentation

◆ ISimulatedWorldMsgsImpl()

ISimulatedWorldMsgsImpl::ISimulatedWorldMsgsImpl ( yarp::dev::ISimulatedWorld *  iSim)

Definition at line 302 of file SimulatedWorld_nws_yarp.cpp.

◆ ~ISimulatedWorldMsgsImpl()

ISimulatedWorldMsgsImpl::~ISimulatedWorldMsgsImpl ( )
default

Member Function Documentation

◆ attach()

ReturnValue ISimulatedWorldMsgsImpl::attach ( const std::string &  id,
const std::string &  link_name 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 97 of file SimulatedWorld_nws_yarp.cpp.

◆ changeColor()

ReturnValue ISimulatedWorldMsgsImpl::changeColor ( const std::string &  id,
const yarp::sig::ColorRGB &  color 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 108 of file SimulatedWorld_nws_yarp.cpp.

◆ deleteAll()

ReturnValue ISimulatedWorldMsgsImpl::deleteAll ( )
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 130 of file SimulatedWorld_nws_yarp.cpp.

◆ deleteObject()

ReturnValue ISimulatedWorldMsgsImpl::deleteObject ( const std::string &  id)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 119 of file SimulatedWorld_nws_yarp.cpp.

◆ detach()

ReturnValue ISimulatedWorldMsgsImpl::detach ( const std::string &  id)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 240 of file SimulatedWorld_nws_yarp.cpp.

◆ enableCollision()

ReturnValue ISimulatedWorldMsgsImpl::enableCollision ( const std::string &  id,
const bool  enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 141 of file SimulatedWorld_nws_yarp.cpp.

◆ enableGravity()

ReturnValue ISimulatedWorldMsgsImpl::enableGravity ( const std::string &  id,
const bool  enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 152 of file SimulatedWorld_nws_yarp.cpp.

◆ getList()

getListReturnValue ISimulatedWorldMsgsImpl::getList ( )
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 262 of file SimulatedWorld_nws_yarp.cpp.

◆ getMutex()

std::mutex * ISimulatedWorldMsgsImpl::getMutex ( )
inline

Definition at line 62 of file SimulatedWorld_nws_yarp.h.

◆ getPose()

getPoseReturnValue ISimulatedWorldMsgsImpl::getPose ( const std::string &  id,
const std::string &  frame_name 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 282 of file SimulatedWorld_nws_yarp.cpp.

◆ makeActor()

ReturnValue ISimulatedWorldMsgsImpl::makeActor ( const std::string &  id_name,
const std::string &  skin_filename,
const std::string &  actor_filename,
const yarp::sig::Pose6D &  pose 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 229 of file SimulatedWorld_nws_yarp.cpp.

◆ makeBox()

ReturnValue ISimulatedWorldMsgsImpl::makeBox ( const std::string &  id_name,
const double  width,
const double  height,
const double  thickness,
const yarp::sig::Pose6D &  pose,
const yarp::sig::ColorRGB &  color,
const std::string &  frame_name,
const bool  gravity_enable,
const bool  collision_enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 185 of file SimulatedWorld_nws_yarp.cpp.

◆ makeCylinder()

ReturnValue ISimulatedWorldMsgsImpl::makeCylinder ( const std::string &  id_name,
const double  radius,
const double  length,
const yarp::sig::Pose6D &  pose,
const yarp::sig::ColorRGB &  color,
const std::string &  frame_name,
const bool  gravity_enable,
const bool  collision_enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 196 of file SimulatedWorld_nws_yarp.cpp.

◆ makeFrame()

ReturnValue ISimulatedWorldMsgsImpl::makeFrame ( const std::string &  id_name,
const double  size,
const yarp::sig::Pose6D &  pose,
const yarp::sig::ColorRGB &  color,
const std::string &  frame_name,
const bool  gravity_enable,
const bool  collision_enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 207 of file SimulatedWorld_nws_yarp.cpp.

◆ makeModel()

ReturnValue ISimulatedWorldMsgsImpl::makeModel ( const std::string &  id_name,
const std::string &  filename,
const yarp::sig::Pose6D &  pose,
const std::string &  frame_name,
const bool  gravity_enable,
const bool  collision_enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 218 of file SimulatedWorld_nws_yarp.cpp.

◆ makeSphere()

ReturnValue ISimulatedWorldMsgsImpl::makeSphere ( const std::string &  id_name,
const double  radius,
const yarp::sig::Pose6D &  pose,
const yarp::sig::ColorRGB &  color,
const std::string &  frame_name,
const bool  gravity_enable,
const bool  collision_enable 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 174 of file SimulatedWorld_nws_yarp.cpp.

◆ rename()

ReturnValue ISimulatedWorldMsgsImpl::rename ( const std::string &  old_name,
const std::string &  new_name 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 251 of file SimulatedWorld_nws_yarp.cpp.

◆ setPose()

ReturnValue ISimulatedWorldMsgsImpl::setPose ( const std::string &  id,
const yarp::sig::Pose6D &  pose,
const std::string &  frame_name = "" 
)
overridevirtual

Reimplemented from ISimulatedWorldMsgs.

Definition at line 163 of file SimulatedWorld_nws_yarp.cpp.


The documentation for this class was generated from the following files: