YARP
Yet Another Robot Platform
 
Loading...
Searching...
No Matches
ControlBoardMsgs_setInteractionModeOneRPC_helper Class Reference
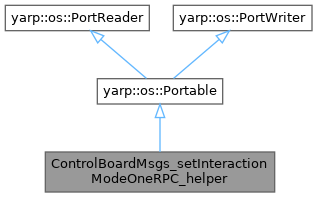
+ Inheritance diagram for ControlBoardMsgs_setInteractionModeOneRPC_helper:

Classes

class  Command
 
class  Reply
 

Public Types

using funcptr_t = yarp::dev::ReturnValue(*)(const std::int32_t, const yarp::dev::InteractionModeEnum)
 

Public Member Functions

 ControlBoardMsgs_setInteractionModeOneRPC_helper ()=default
 
 ControlBoardMsgs_setInteractionModeOneRPC_helper (const std::int32_t axis, const yarp::dev::InteractionModeEnum mode)
 
bool write (yarp::os::ConnectionWriter &connection) const override
 Write this object to a network connection.
 
bool read (yarp::os::ConnectionReader &connection) override
 Read this object from a network connection.
 
void call (ControlBoardMsgs *ptr)
 
- Public Member Functions inherited from yarp::os::Portable
virtual Type getType () const
 
- Public Member Functions inherited from yarp::os::PortReader
virtual ~PortReader ()
 Destructor.
 
virtual Type getReadType () const
 
- Public Member Functions inherited from yarp::os::PortWriter
virtual ~PortWriter ()
 Destructor.
 
virtual void onCompletion () const
 This is called when the port has finished all writing operations.
 
virtual void onCommencement () const
 This is called when the port is about to begin writing operations.
 
virtual yarp::os::Type getWriteType () const
 

Public Attributes

Command cmd
 
Reply reply
 

Static Public Attributes

static constexpr const char * s_tag {"setInteractionModeOneRPC"}
 
static constexpr size_t s_tag_len {1}
 
static constexpr size_t s_cmd_len {3}
 
static constexpr size_t s_reply_len {1}
 
static constexpr const char * s_prototype {"yarp::dev::ReturnValue ControlBoardMsgs::setInteractionModeOneRPC(const std::int32_t axis, const yarp::dev::InteractionModeEnum mode)"}
 
static constexpr const char * s_help {""}
 

Additional Inherited Members

- Static Public Member Functions inherited from yarp::os::Portable
static bool copyPortable (const PortWriter &writer, PortReader &reader)
 Copy one portable to another, via writing and reading.
 

Detailed Description

Definition at line 980 of file ControlBoardMsgs.cpp.

Member Typedef Documentation

◆ funcptr_t

Constructor & Destructor Documentation

◆ ControlBoardMsgs_setInteractionModeOneRPC_helper() [1/2]

ControlBoardMsgs_setInteractionModeOneRPC_helper::ControlBoardMsgs_setInteractionModeOneRPC_helper ( )
default

◆ ControlBoardMsgs_setInteractionModeOneRPC_helper() [2/2]

ControlBoardMsgs_setInteractionModeOneRPC_helper::ControlBoardMsgs_setInteractionModeOneRPC_helper ( const std::int32_t  axis,
const yarp::dev::InteractionModeEnum  mode 
)

Definition at line 14275 of file ControlBoardMsgs.cpp.

Member Function Documentation

◆ call()

void ControlBoardMsgs_setInteractionModeOneRPC_helper::call ( ControlBoardMsgs *  ptr)

Definition at line 14431 of file ControlBoardMsgs.cpp.

◆ read()

bool ControlBoardMsgs_setInteractionModeOneRPC_helper::read ( yarp::os::ConnectionReader &  reader)
overridevirtual

Read this object from a network connection.

Override this for your particular class.

Parameters
readeran interface to the network connection for reading
Returns
true iff the object is successfully read

Implements yarp::os::Portable.

Definition at line 14285 of file ControlBoardMsgs.cpp.

◆ write()

bool ControlBoardMsgs_setInteractionModeOneRPC_helper::write ( yarp::os::ConnectionWriter &  writer) const
overridevirtual

Write this object to a network connection.

Override this for your particular class. Be aware that depending on the nature of the connections a port has, and what protocol they use, and how efficient the YARP implementation is, this method may be called once, twice, or many times, as the result of a single call to Port::write

Parameters
writeran interface to the network connection for writing
Returns
true iff the object is successfully written

Implements yarp::os::Portable.

Definition at line 14280 of file ControlBoardMsgs.cpp.

Member Data Documentation

◆ cmd

Command ControlBoardMsgs_setInteractionModeOneRPC_helper::cmd

Definition at line 1032 of file ControlBoardMsgs.cpp.

◆ reply

Reply ControlBoardMsgs_setInteractionModeOneRPC_helper::reply

Definition at line 1033 of file ControlBoardMsgs.cpp.

◆ s_cmd_len

constexpr size_t ControlBoardMsgs_setInteractionModeOneRPC_helper::s_cmd_len {3}
staticconstexpr

Definition at line 1037 of file ControlBoardMsgs.cpp.

◆ s_help

constexpr const char* ControlBoardMsgs_setInteractionModeOneRPC_helper::s_help {""}
staticconstexpr

Definition at line 1040 of file ControlBoardMsgs.cpp.

◆ s_prototype

constexpr const char* ControlBoardMsgs_setInteractionModeOneRPC_helper::s_prototype {"yarp::dev::ReturnValue ControlBoardMsgs::setInteractionModeOneRPC(const std::int32_t axis, const yarp::dev::InteractionModeEnum mode)"}
staticconstexpr

Definition at line 1039 of file ControlBoardMsgs.cpp.

◆ s_reply_len

constexpr size_t ControlBoardMsgs_setInteractionModeOneRPC_helper::s_reply_len {1}
staticconstexpr

Definition at line 1038 of file ControlBoardMsgs.cpp.

◆ s_tag

constexpr const char* ControlBoardMsgs_setInteractionModeOneRPC_helper::s_tag {"setInteractionModeOneRPC"}
staticconstexpr

Definition at line 1035 of file ControlBoardMsgs.cpp.

◆ s_tag_len

constexpr size_t ControlBoardMsgs_setInteractionModeOneRPC_helper::s_tag_len {1}
staticconstexpr

Definition at line 1036 of file ControlBoardMsgs.cpp.


The documentation for this class was generated from the following file: