|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
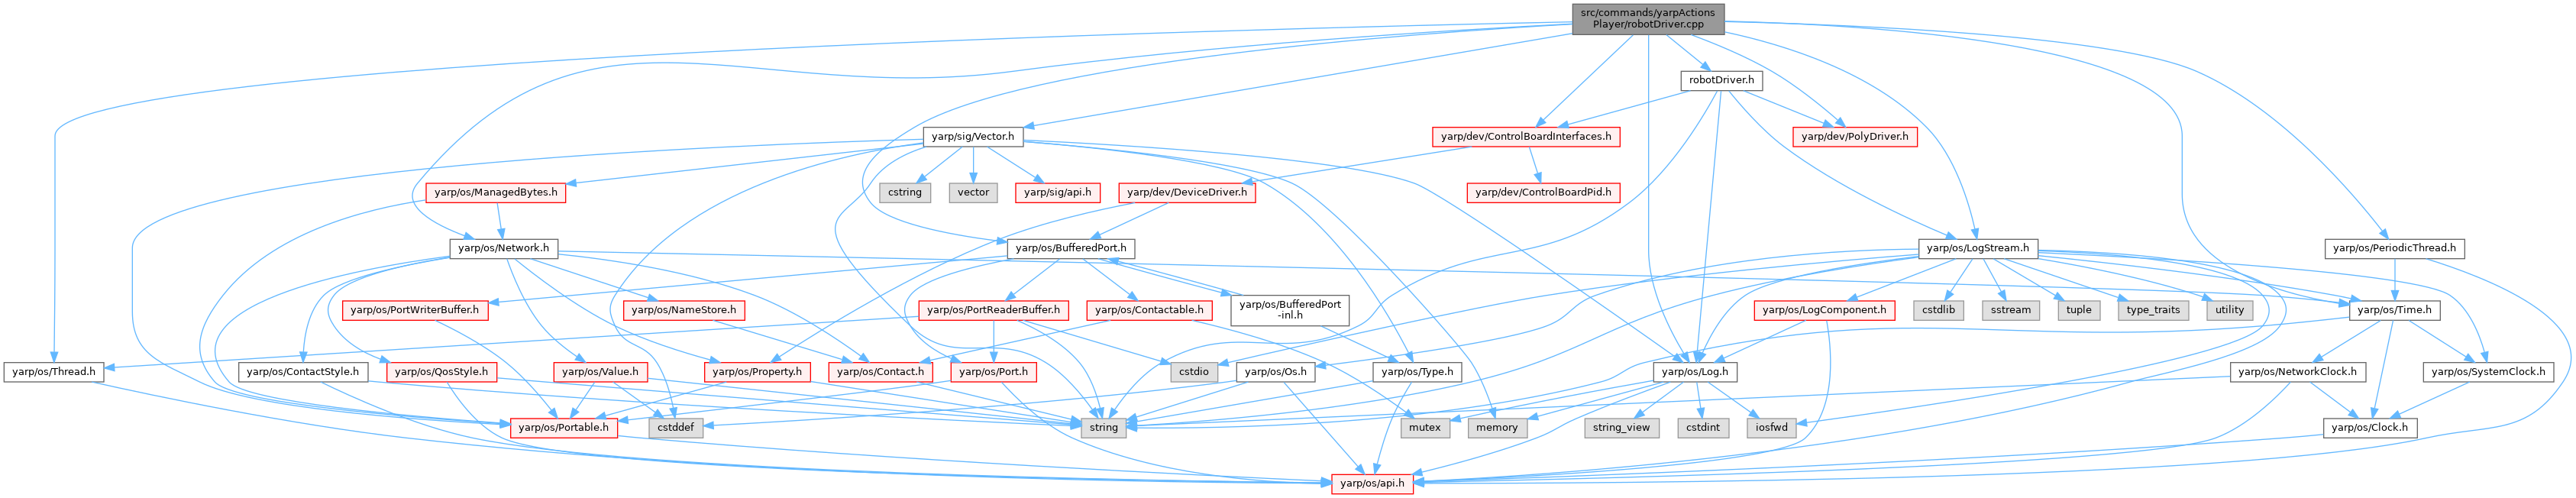
#include <cmath>#include <iomanip>#include <yarp/os/Network.h>#include <yarp/os/Time.h>#include <yarp/os/Log.h>#include <yarp/os/LogStream.h>#include <yarp/os/BufferedPort.h>#include <yarp/sig/Vector.h>#include <yarp/dev/ControlBoardInterfaces.h>#include <yarp/dev/PolyDriver.h>#include <yarp/os/PeriodicThread.h>#include <yarp/os/Thread.h>#include "robotDriver.h" Include dependency graph for robotDriver.cpp:
Go to the source code of this file.
Functions | |
| std::string | vectorToString (const std::vector< double > &vec) |
Definition at line 148 of file robotDriver.cpp.
 1.9.8