#include <yarp/dev/ImplementAxisInfo.h>
|
| bool | initialize (int size, const int *amap) |
| | Initialize the internal data and alloc memory.
|
| |
| bool | uninitialize () |
| | Clean up internal data and memory.
|
| |
Definition at line 15 of file ImplementAxisInfo.h.
◆ ImplementAxisInfo()
◆ ~ImplementAxisInfo()
| ImplementAxisInfo::~ImplementAxisInfo |
( |
| ) |
|
|
virtual |
◆ getAxes()
Get the number of controlled axes.
This command asks the number of controlled axes for the current physical interface.
- Parameters
-
| ax | storage to return param |
- Returns
- true/false.
Implements yarp::dev::IAxisInfo.
Definition at line 62 of file ImplementAxisInfo.cpp.
◆ getAxisName()
| ReturnValue ImplementAxisInfo::getAxisName |
( |
int |
axis, |
|
|
std::string & |
name |
|
) |
| |
|
overridevirtual |
◆ getJointType()
◆ initialize()
| bool ImplementAxisInfo::initialize |
( |
int |
size, |
|
|
const int * |
amap |
|
) |
| |
|
protected |
Initialize the internal data and alloc memory.
- Parameters
-
| size | is the number of controlled axes the driver deals with. |
| amap | is a lookup table mapping axes onto physical drivers. |
- Returns
- true if initialized succeeded, false if it wasn't executed, or assert.
Definition at line 30 of file ImplementAxisInfo.cpp.
◆ uninitialize()
| bool ImplementAxisInfo::uninitialize |
( |
| ) |
|
|
protected |
Clean up internal data and memory.
- Returns
- true if uninitialization is executed, false otherwise.
Definition at line 49 of file ImplementAxisInfo.cpp.
◆ m_buffer_doubles
| std::vector<double> yarp::dev::ImplementAxisInfo::m_buffer_doubles |
|
protected |
◆ m_buffer_doubles2
| std::vector<double> yarp::dev::ImplementAxisInfo::m_buffer_doubles2 |
|
protected |
◆ m_buffer_ints
| std::vector<int> yarp::dev::ImplementAxisInfo::m_buffer_ints |
|
protected |
◆ m_helper
| void* yarp::dev::ImplementAxisInfo::m_helper =nullptr |
|
protected |
◆ m_imp_mutex
| std::mutex yarp::dev::ImplementAxisInfo::m_imp_mutex |
|
protected |
◆ m_iraw
The documentation for this class was generated from the following files:


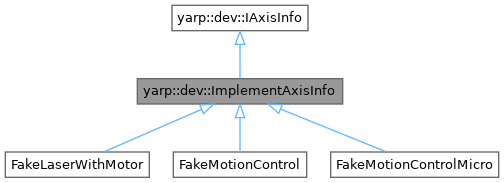
 Inheritance diagram for yarp::dev::ImplementAxisInfo:
 1.9.8