|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
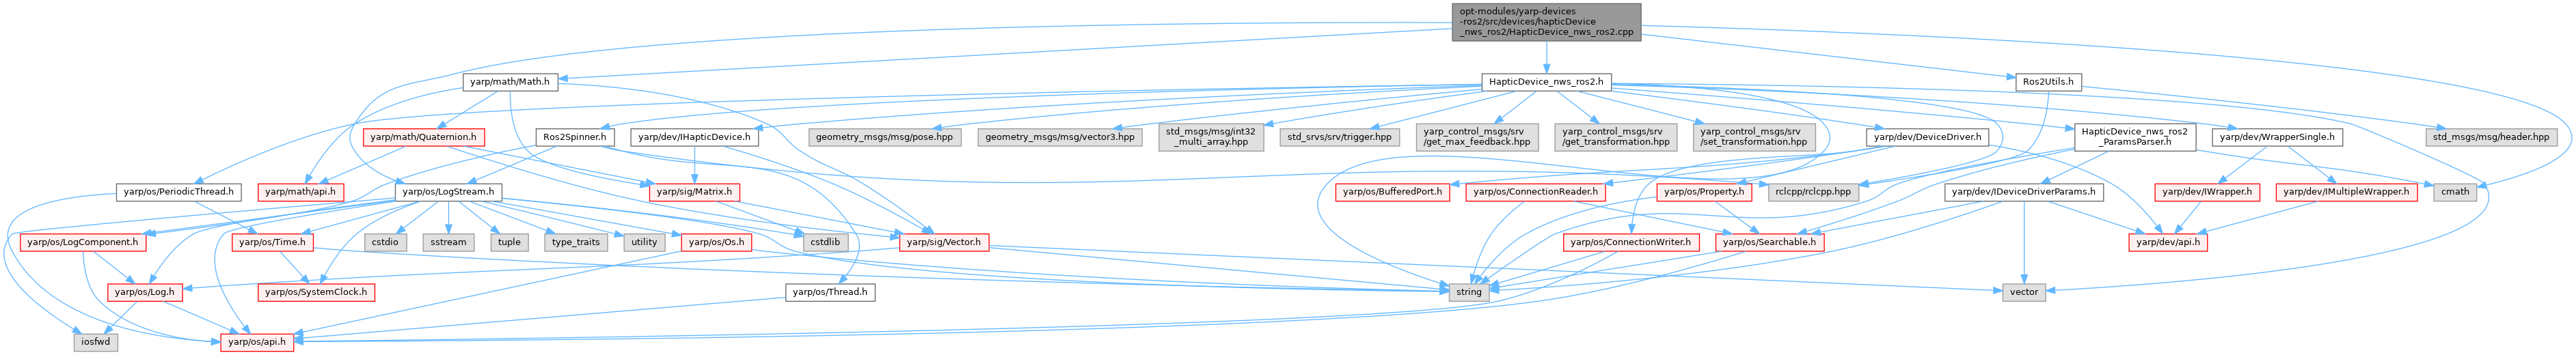
#include "HapticDevice_nws_ros2.h"#include <cmath>#include <yarp/math/Math.h>#include <yarp/os/LogStream.h>#include <Ros2Utils.h> Include dependency graph for HapticDevice_nws_ros2.cpp:
Go to the source code of this file.
Functions | |
| const yarp::os::LogComponent & | HAPTICDEVICE_NWS_ROS2 () |
| const yarp::os::LogComponent & HAPTICDEVICE_NWS_ROS2 | ( | ) |
Definition at line 10 of file HapticDevice_nws_ros2.cpp.
 1.9.8