|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
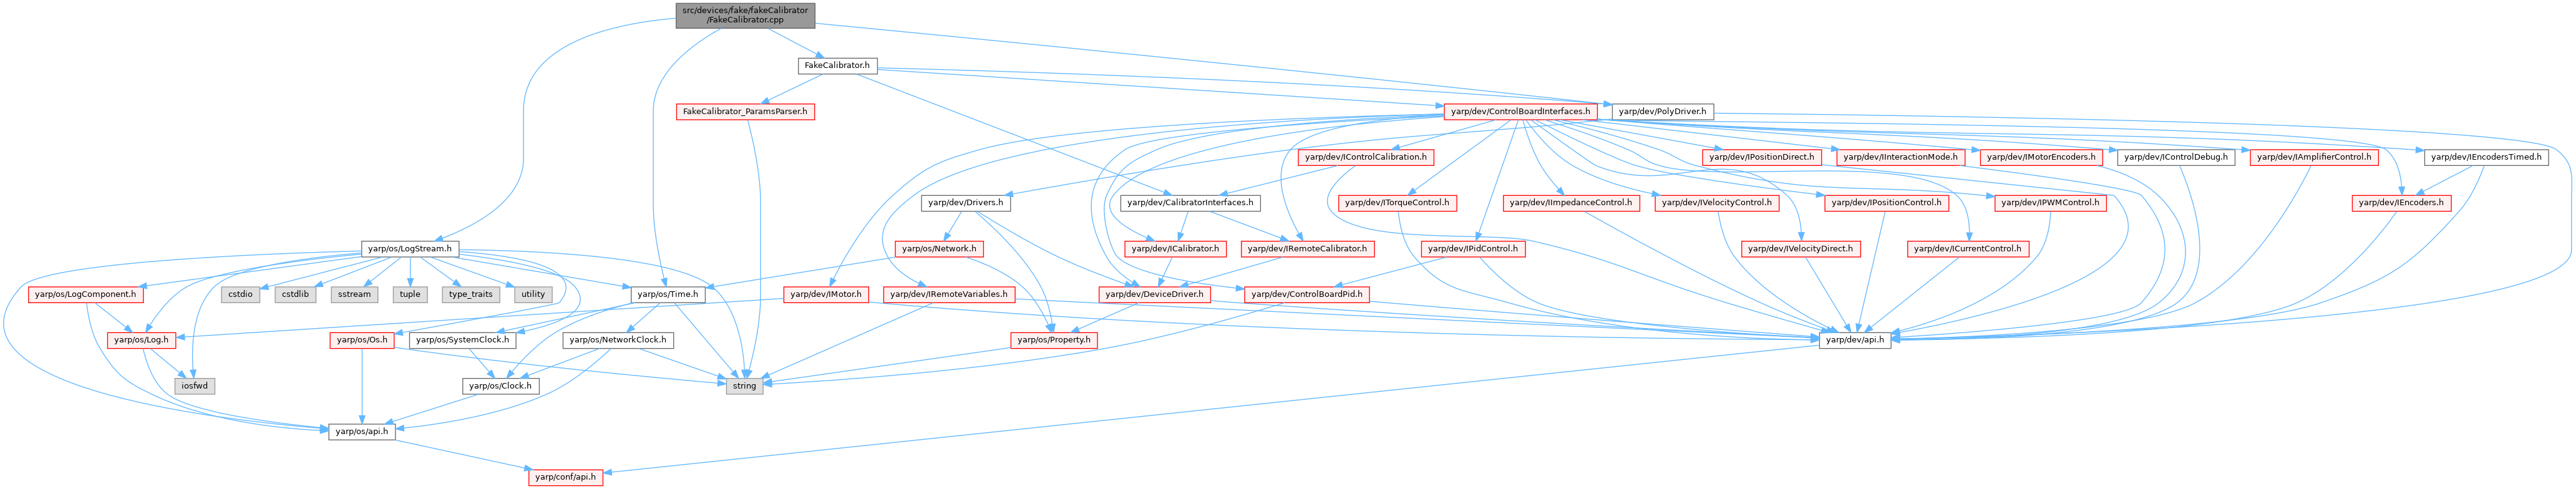
#include <yarp/os/Time.h>#include <yarp/dev/PolyDriver.h>#include "FakeCalibrator.h"#include <yarp/os/LogStream.h> Include dependency graph for FakeCalibrator.cpp:
 1.9.8