|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
 Collaboration diagram for FrameTransform: possibile server-client configurations with external devices:
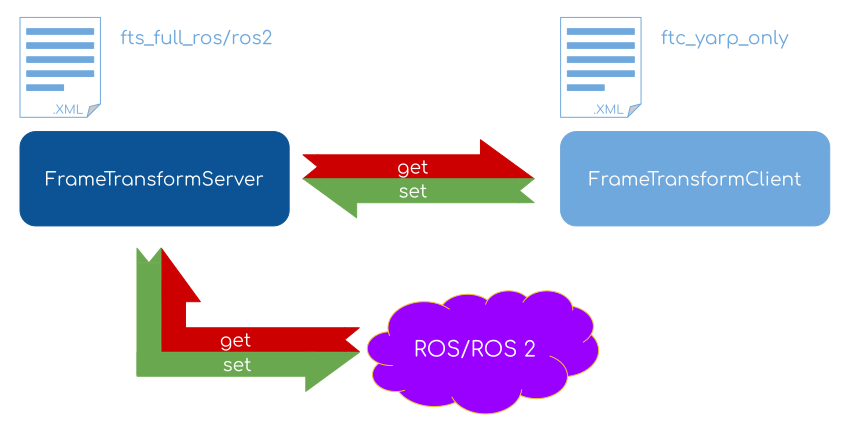
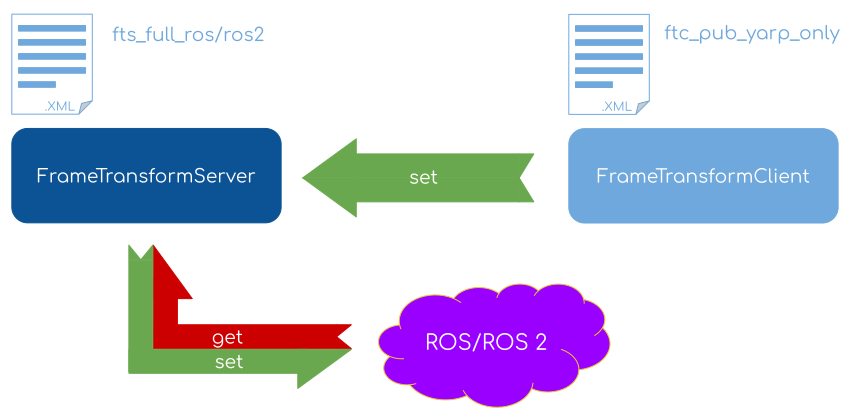
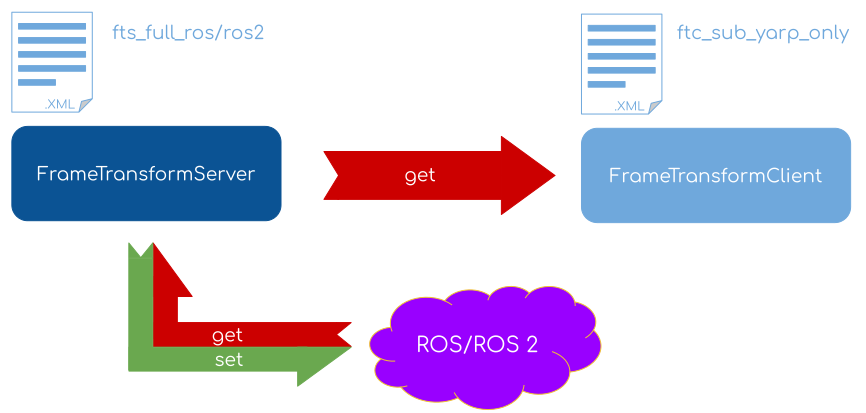
FrameTransformServer and FrameTransformClient with externals devices, comes new client/server coupling configurations. In order to facilitate the use of these new devices, here is a complete list of the allowed combinations.
In the following configurations the communication with ROS/ROS2 is managed by the server. These configurations are particularly useful when all the clients that are going to connect to the server need to have access to the transform published on ROS/ROS2 topics
In the following configurations the communication with ROS/ROS2 is managed by the client. These are particolarly useful when the server and other clients are running on machines with no ROS/ROS2 support but need the TFs generated by those middlewares
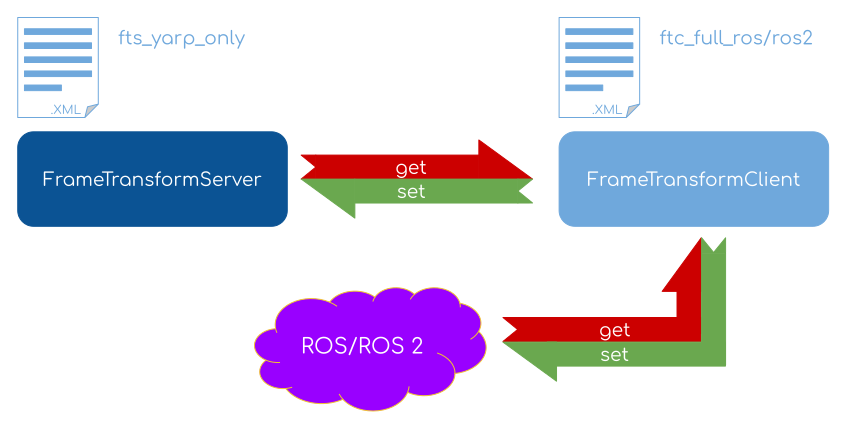
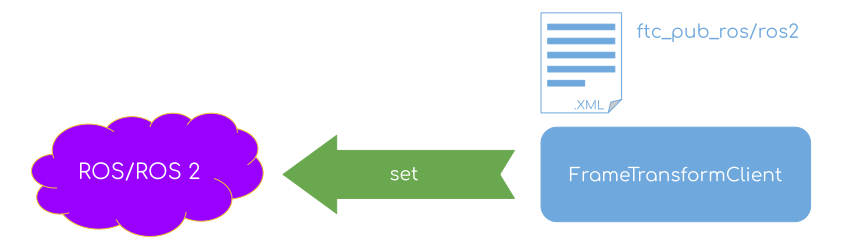
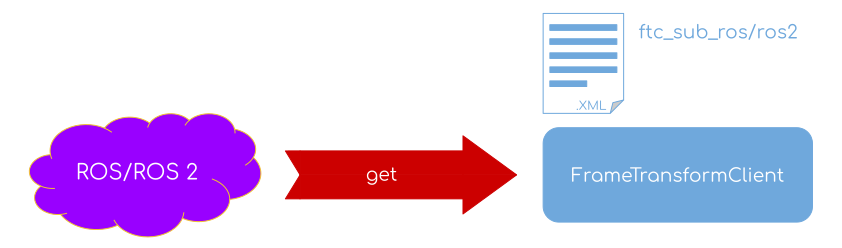
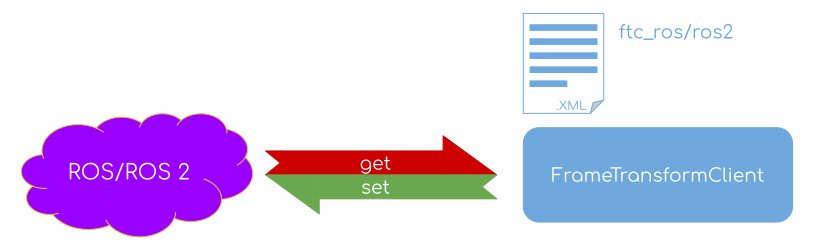
In the following configurations, the client will only communicate with ROS/ROS2 TF topics. These configurations are useful when a YARP client has to interface with a ROS/ROS2 only system and needs to get and set TFs from/to ROS/ROS2 topics
 1.9.8