|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
#include <yarp/dev/ImplementVelocityControl.h>
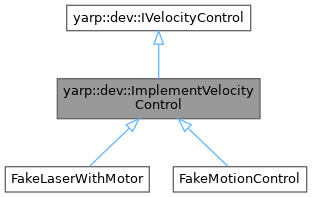
 Inheritance diagram for yarp::dev::ImplementVelocityControl:
Public Member Functions | |
| ImplementVelocityControl (yarp::dev::IVelocityControlRaw *y) | |
| Constructor. | |
| virtual | ~ImplementVelocityControl () |
| Destructor. | |
| yarp::dev::ReturnValue | getAxes (size_t &axes) override |
| Get the number of controlled axes. | |
| yarp::dev::ReturnValue | velocityMove (int j, double sp) override |
| Start motion at a given speed, single joint. | |
| yarp::dev::ReturnValue | velocityMove (const double *sp) override |
| Start motion at a given speed, multiple joints. | |
| yarp::dev::ReturnValue | setTrajAcceleration (int j, double acc) override |
| Set reference acceleration for a joint. | |
| yarp::dev::ReturnValue | setTrajAccelerations (const double *accs) override |
| Set reference acceleration on all joints. | |
| yarp::dev::ReturnValue | getTrajAcceleration (int j, double *acc) override |
| Get reference acceleration for a joint. | |
| yarp::dev::ReturnValue | getTrajAccelerations (double *accs) override |
| Get reference acceleration of all joints. | |
| yarp::dev::ReturnValue | stop (int j) override |
| Stop motion, single joint. | |
| yarp::dev::ReturnValue | stop () override |
| Stop motion, multiple joints. | |
| yarp::dev::ReturnValue | velocityMove (const int n_joint, const int *joints, const double *spds) override |
| Start motion at a given speed for a subset of joints. | |
| yarp::dev::ReturnValue | getTargetVelocity (const int joint, double *vel) override |
| Get the last reference speed set by velocityMove for single joint. | |
| yarp::dev::ReturnValue | getTargetVelocities (double *vels) override |
| Get the last reference speed set by velocityMove for all joints. | |
| yarp::dev::ReturnValue | getTargetVelocities (const int n_joint, const int *joints, double *vels) override |
| Get the last reference speed set by velocityMove for a group of joints. | |
| yarp::dev::ReturnValue | setTrajAccelerations (const int n_joint, const int *joints, const double *accs) override |
| Set reference acceleration for a subset of joints. | |
| yarp::dev::ReturnValue | getTrajAccelerations (const int n_joint, const int *joints, double *accs) override |
| Get reference acceleration for a subset of joints. | |
| yarp::dev::ReturnValue | stop (const int n_joint, const int *joints) override |
| Stop motion for a subset of joints. | |
| Public Member Functions inherited from yarp::dev::IVelocityControl | |
| virtual | ~IVelocityControl () |
| Destructor. | |
Protected Member Functions | |
| bool | initialize (int size, const int *amap, const double *enc, const double *zos) |
| Initialize the internal data and alloc memory. | |
| bool | uninitialize () |
| Clean up internal data and memory. | |
Protected Attributes | |
| IVelocityControlRaw * | m_iraw =nullptr |
| void * | m_helper =nullptr |
| std::vector< int > | m_buffer_ints |
| std::vector< double > | m_buffer_doubles |
| std::mutex | m_imp_mutex |
Definition at line 26 of file ImplementVelocityControl.h.
| ImplementVelocityControl::ImplementVelocityControl | ( | yarp::dev::IVelocityControlRaw * | y | ) |
Constructor.
| y | is the pointer to the class instance inheriting from this implementation. |
Definition at line 21 of file ImplementVelocityControl.cpp.
|
virtual |
Destructor.
Definition at line 26 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get the number of controlled axes.
This command asks the number of controlled axes for the current physical interface. param axes pointer to storage
Implements yarp::dev::IVelocityControl.
Definition at line 57 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get the last reference speed set by velocityMove for a group of joints.
| n_joint | how many joints this command is referring to |
| joints | of joints controlled. The size of this array is n_joints |
| vels | pointer to the array containing the requested values, one value for each joint. The size of the array is n_joints. |
Implements yarp::dev::IVelocityControl.
Definition at line 128 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get the last reference speed set by velocityMove for all joints.
| vels | pointer to the array containing the new speed values, one value for each joint |
Implements yarp::dev::IVelocityControl.
Definition at line 118 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get the last reference speed set by velocityMove for single joint.
| j | joint number |
| vel | returns the requested reference. |
Implements yarp::dev::IVelocityControl.
Definition at line 104 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get reference acceleration for a joint.
Returns the acceleration used to generate the trajectory profile.
| j | joint number |
| acc | pointer to storage for the return value |
Implements yarp::dev::IVelocityControl.
Definition at line 193 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get reference acceleration for a subset of joints.
These are the values used during the interpolation of the trajectory.
| n_joint | how many joints this command is referring to |
| joints | list of joints controlled. The size of this array is n_joints |
| accs | pointer to the array containing acceleration values, one value for each joint, the size of the array is n_joints. The first value will be the new reference for the joint joints[0]. for example: n_joint 3 joints 0 2 4 accs 10 30 40 |
Implements yarp::dev::IVelocityControl.
Definition at line 207 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Get reference acceleration of all joints.
These are the values used during the interpolation of the trajectory.
| accs | pointer to the array that will store the acceleration values. |
Implements yarp::dev::IVelocityControl.
Definition at line 233 of file ImplementVelocityControl.cpp.
|
protected |
Initialize the internal data and alloc memory.
| size | is the number of controlled axes the driver deals with. |
| amap | is a lookup table mapping axes onto physical drivers. |
| enc | is an array containing the encoder to angles conversion factors. |
| zos | is an array containing the zeros of the encoders. respect to the control/output values of the driver. |
Definition at line 31 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Set reference acceleration for a joint.
This value is used during the trajectory generation.
| j | joint number |
| acc | acceleration value |
Implements yarp::dev::IVelocityControl.
Definition at line 153 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Set reference acceleration on all joints.
This is the value that is used during the generation of the trajectory.
| accs | pointer to the array of acceleration values |
Implements yarp::dev::IVelocityControl.
Definition at line 183 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Set reference acceleration for a subset of joints.
This is the value that is used during the generation of the trajectory.
| n_joint | how many joints this command is referring to |
| joints | list of joints controlled. The size of this array is n_joints |
| accs | pointer to the array containing acceleration values, one value for each joint, the size of the array is n_joints. The first value will be the new reference for the joint joints[0]. for example: n_joint 3 joints 0 2 4 accs 10 30 40 |
Implements yarp::dev::IVelocityControl.
Definition at line 164 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Stop motion, multiple joints.
Implements yarp::dev::IVelocityControl.
Definition at line 270 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Stop motion for a subset of joints.
| n_joint | how many joints this command is referring to |
| joints | joints pointer to the array of joint numbers |
Implements yarp::dev::IVelocityControl.
Definition at line 255 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Stop motion, single joint.
| j | joint number |
Implements yarp::dev::IVelocityControl.
Definition at line 244 of file ImplementVelocityControl.cpp.
|
protected |
Clean up internal data and memory.
Definition at line 46 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Start motion at a given speed, multiple joints.
| sp | pointer to the array containing the new speed values |
Implements yarp::dev::IVelocityControl.
Definition at line 94 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Start motion at a given speed for a subset of joints.
| n_joint | how many joints this command is referring to |
| joints | of joints controlled. The size of this array is n_joints |
| spds | pointer to the array containing the new speed values, one value for each joint, the size of the array is n_joints. The first value will be the new reference for the joint joints[0]. for example: n_joint 3 joints 0 2 4 spds 10 30 40 |
Implements yarp::dev::IVelocityControl.
Definition at line 74 of file ImplementVelocityControl.cpp.
|
overridevirtual |
Start motion at a given speed, single joint.
| j | joint number |
| sp | speed value |
Implements yarp::dev::IVelocityControl.
Definition at line 63 of file ImplementVelocityControl.cpp.
|
protected |
Definition at line 32 of file ImplementVelocityControl.h.
|
protected |
Definition at line 31 of file ImplementVelocityControl.h.
|
protected |
Definition at line 30 of file ImplementVelocityControl.h.
|
protected |
Definition at line 33 of file ImplementVelocityControl.h.
|
protected |
Definition at line 29 of file ImplementVelocityControl.h.
 1.9.8