|
YARP
Yet Another Robot Platform
|

|
|
YARP
Yet Another Robot Platform
|
|
This class is the parameters parser for class SimulatedWorld_nws_ros2. More...
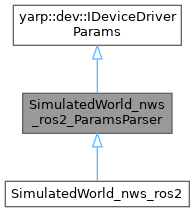
 Inheritance diagram for SimulatedWorld_nws_ros2_ParamsParser:
Classes | |
| struct | parser_version_type |
Public Member Functions | |
| SimulatedWorld_nws_ros2_ParamsParser () | |
| ~SimulatedWorld_nws_ros2_ParamsParser () override=default | |
| bool | parseParams (const yarp::os::Searchable &config) override |
| Parse the DeviceDriver parameters. | |
| std::string | getDeviceClassName () const override |
| Get the name of the DeviceDriver class. | |
| std::string | getDeviceName () const override |
| Get the name of the device (i.e. | |
| std::string | getDocumentationOfDeviceParams () const override |
| Get the documentation of the DeviceDriver's parameters. | |
| std::vector< std::string > | getListOfParams () const override |
| Return a list of all params used by the device. | |
| bool | getParamValue (const std::string ¶mName, std::string ¶mValue) const override |
| Return the value (represented as a string) of the requested parameter. | |
| std::string | getConfiguration () const override |
| Return the configuration of the device. | |
| Public Member Functions inherited from yarp::dev::IDeviceDriverParams | |
| virtual | ~IDeviceDriverParams () |
Public Attributes | |
| const std::string | m_device_classname = {"SimulatedWorld_nws_ros2"} |
| const std::string | m_device_name = {"simulatedWorld_nws_ros2"} |
| bool | m_parser_is_strict = false |
| const parser_version_type | m_parser_version = {} |
| std::string | m_provided_configuration |
| const std::string | m_node_name_defaultValue = {"simulatedWorld_nws_ros2"} |
| const std::string | m_namespace_defaultValue = {""} |
| const std::string | m_makesphere_servicename_defaultValue = {"makeSphere"} |
| const std::string | m_makebox_servicename_defaultValue = {"makeBox"} |
| const std::string | m_makecylinder_servicename_defaultValue = {"makeCylinder"} |
| const std::string | m_makeframe_servicename_defaultValue = {"makeFrame"} |
| const std::string | m_makemodel_servicename_defaultValue = {"makeModel"} |
| const std::string | m_makeactor_servicename_defaultValue = {"makeActor"} |
| const std::string | m_changecolor_servicename_defaultValue = {"changeColor"} |
| const std::string | m_setpose_servicename_defaultValue = {"setPose"} |
| const std::string | m_enablegravity_servicename_defaultValue = {"enableGravity"} |
| const std::string | m_enablecollision_servicename_defaultValue = {"enableCollision"} |
| const std::string | m_getpose_servicename_defaultValue = {"getPose"} |
| const std::string | m_deleteobject_servicename_defaultValue = {"deleteObject"} |
| const std::string | m_deleteall_servicename_defaultValue = {"deleteAll"} |
| const std::string | m_getlist_servicename_defaultValue = {"getList"} |
| const std::string | m_attach_servicename_defaultValue = {"attach"} |
| const std::string | m_detach_servicename_defaultValue = {"detach"} |
| const std::string | m_rename_servicename_defaultValue = {"rename"} |
| std::string | m_node_name = {"simulatedWorld_nws_ros2"} |
| std::string | m_namespace = {} |
| std::string | m_makesphere_servicename = {"makeSphere"} |
| std::string | m_makebox_servicename = {"makeBox"} |
| std::string | m_makecylinder_servicename = {"makeCylinder"} |
| std::string | m_makeframe_servicename = {"makeFrame"} |
| std::string | m_makemodel_servicename = {"makeModel"} |
| std::string | m_makeactor_servicename = {"makeActor"} |
| std::string | m_changecolor_servicename = {"changeColor"} |
| std::string | m_setpose_servicename = {"setPose"} |
| std::string | m_enablegravity_servicename = {"enableGravity"} |
| std::string | m_enablecollision_servicename = {"enableCollision"} |
| std::string | m_getpose_servicename = {"getPose"} |
| std::string | m_deleteobject_servicename = {"deleteObject"} |
| std::string | m_deleteall_servicename = {"deleteAll"} |
| std::string | m_getlist_servicename = {"getList"} |
| std::string | m_attach_servicename = {"attach"} |
| std::string | m_detach_servicename = {"detach"} |
| std::string | m_rename_servicename = {"rename"} |
This class is the parameters parser for class SimulatedWorld_nws_ros2.
These are the used parameters:
| Group name | Parameter name | Type | Units | Default Value | Required | Description | Notes |
|---|---|---|---|---|---|---|---|
| - | node_name | string | - | simulatedWorld_nws_ros2 | 0 | The ROS2 node name | - |
| - | namespace | string | - | - | 0 | optional namespace for ros2 node | - |
| - | makesphere_servicename | string | - | makeSphere | 0 | ROS2 service name for makeSphere | - |
| - | makebox_servicename | string | - | makeBox | 0 | ROS2 service name for makeBox | - |
| - | makecylinder_servicename | string | - | makeCylinder | 0 | ROS2 service name for makeCylinder | - |
| - | makeframe_servicename | string | - | makeFrame | 0 | ROS2 service name for makeFrame | - |
| - | makemodel_servicename | string | - | makeModel | 0 | ROS2 service name for makeModel | - |
| - | makeactor_servicename | string | - | makeActor | 0 | ROS2 service name for makeActor | - |
| - | changecolor_servicename | string | - | changeColor | 0 | ROS2 service name for changeColor | - |
| - | setpose_servicename | string | - | setPose | 0 | ROS2 service name for setPose | - |
| - | enablegravity_servicename | string | - | enableGravity | 0 | ROS2 service name for enableGravity | - |
| - | enablecollision_servicename | string | - | enableCollision | 0 | ROS2 service name for enableCollision | - |
| - | getpose_servicename | string | - | getPose | 0 | ROS2 service name for getPose | - |
| - | deleteobject_servicename | string | - | deleteObject | 0 | ROS2 service name for deleteObject | - |
| - | deleteall_servicename | string | - | deleteAll | 0 | ROS2 service name for deleteAll | - |
| - | getlist_servicename | string | - | getList | 0 | ROS2 service name for getList | - |
| - | attach_servicename | string | - | attach | 0 | ROS2 service name for attach | - |
| - | detach_servicename | string | - | detach | 0 | ROS2 service name for detach | - |
| - | rename_servicename | string | - | rename | 0 | ROS2 service name for rename | - |
The device can be launched by yarpdev using one of the following examples (with and without all optional parameters):
Definition at line 59 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| SimulatedWorld_nws_ros2_ParamsParser::SimulatedWorld_nws_ros2_ParamsParser | ( | ) |
Definition at line 23 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
|
overridedefault |
|
overridevirtual |
Return the configuration of the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 158 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
|
inlineoverridevirtual |
Get the name of the DeviceDriver class.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 119 of file SimulatedWorld_nws_ros2_ParamsParser.h.
|
inlineoverridevirtual |
Get the name of the device (i.e.
the plugin name).
Implements yarp::dev::IDeviceDriverParams.
Definition at line 120 of file SimulatedWorld_nws_ros2_ParamsParser.h.
|
overridevirtual |
Get the documentation of the DeviceDriver's parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 473 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Return a list of all params used by the device.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 28 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Return the value (represented as a string) of the requested parameter.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 54 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
|
overridevirtual |
Parse the DeviceDriver parameters.
Implements yarp::dev::IDeviceDriverParams.
Definition at line 168 of file SimulatedWorld_nws_ros2_ParamsParser.cpp.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_attach_servicename = {"attach"} |
Definition at line 114 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_attach_servicename_defaultValue = {"attach"} |
Definition at line 94 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_changecolor_servicename = {"changeColor"} |
Definition at line 106 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_changecolor_servicename_defaultValue = {"changeColor"} |
Definition at line 86 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_deleteall_servicename = {"deleteAll"} |
Definition at line 112 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_deleteall_servicename_defaultValue = {"deleteAll"} |
Definition at line 92 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_deleteobject_servicename = {"deleteObject"} |
Definition at line 111 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_deleteobject_servicename_defaultValue = {"deleteObject"} |
Definition at line 91 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_detach_servicename = {"detach"} |
Definition at line 115 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_detach_servicename_defaultValue = {"detach"} |
Definition at line 95 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_device_classname = {"SimulatedWorld_nws_ros2"} |
Definition at line 66 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_device_name = {"simulatedWorld_nws_ros2"} |
Definition at line 67 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_enablecollision_servicename = {"enableCollision"} |
Definition at line 109 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_enablecollision_servicename_defaultValue = {"enableCollision"} |
Definition at line 89 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_enablegravity_servicename = {"enableGravity"} |
Definition at line 108 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_enablegravity_servicename_defaultValue = {"enableGravity"} |
Definition at line 88 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_getlist_servicename = {"getList"} |
Definition at line 113 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_getlist_servicename_defaultValue = {"getList"} |
Definition at line 93 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_getpose_servicename = {"getPose"} |
Definition at line 110 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_getpose_servicename_defaultValue = {"getPose"} |
Definition at line 90 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makeactor_servicename = {"makeActor"} |
Definition at line 105 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makeactor_servicename_defaultValue = {"makeActor"} |
Definition at line 85 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makebox_servicename = {"makeBox"} |
Definition at line 101 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makebox_servicename_defaultValue = {"makeBox"} |
Definition at line 81 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makecylinder_servicename = {"makeCylinder"} |
Definition at line 102 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makecylinder_servicename_defaultValue = {"makeCylinder"} |
Definition at line 82 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makeframe_servicename = {"makeFrame"} |
Definition at line 103 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makeframe_servicename_defaultValue = {"makeFrame"} |
Definition at line 83 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makemodel_servicename = {"makeModel"} |
Definition at line 104 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makemodel_servicename_defaultValue = {"makeModel"} |
Definition at line 84 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_makesphere_servicename = {"makeSphere"} |
Definition at line 100 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_makesphere_servicename_defaultValue = {"makeSphere"} |
Definition at line 80 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_namespace = {} |
Definition at line 99 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_namespace_defaultValue = {""} |
Definition at line 79 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_node_name = {"simulatedWorld_nws_ros2"} |
Definition at line 98 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_node_name_defaultValue = {"simulatedWorld_nws_ros2"} |
Definition at line 78 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| bool SimulatedWorld_nws_ros2_ParamsParser::m_parser_is_strict = false |
Definition at line 68 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const parser_version_type SimulatedWorld_nws_ros2_ParamsParser::m_parser_version = {} |
Definition at line 74 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_provided_configuration |
Definition at line 76 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_rename_servicename = {"rename"} |
Definition at line 116 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_rename_servicename_defaultValue = {"rename"} |
Definition at line 96 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| std::string SimulatedWorld_nws_ros2_ParamsParser::m_setpose_servicename = {"setPose"} |
Definition at line 107 of file SimulatedWorld_nws_ros2_ParamsParser.h.
| const std::string SimulatedWorld_nws_ros2_ParamsParser::m_setpose_servicename_defaultValue = {"setPose"} |
Definition at line 87 of file SimulatedWorld_nws_ros2_ParamsParser.h.
 1.9.8