#include <ControlBoardTrajectory.h>
#include <yarp/os/Time.h>
#include <cmath>
Go to the source code of this file.


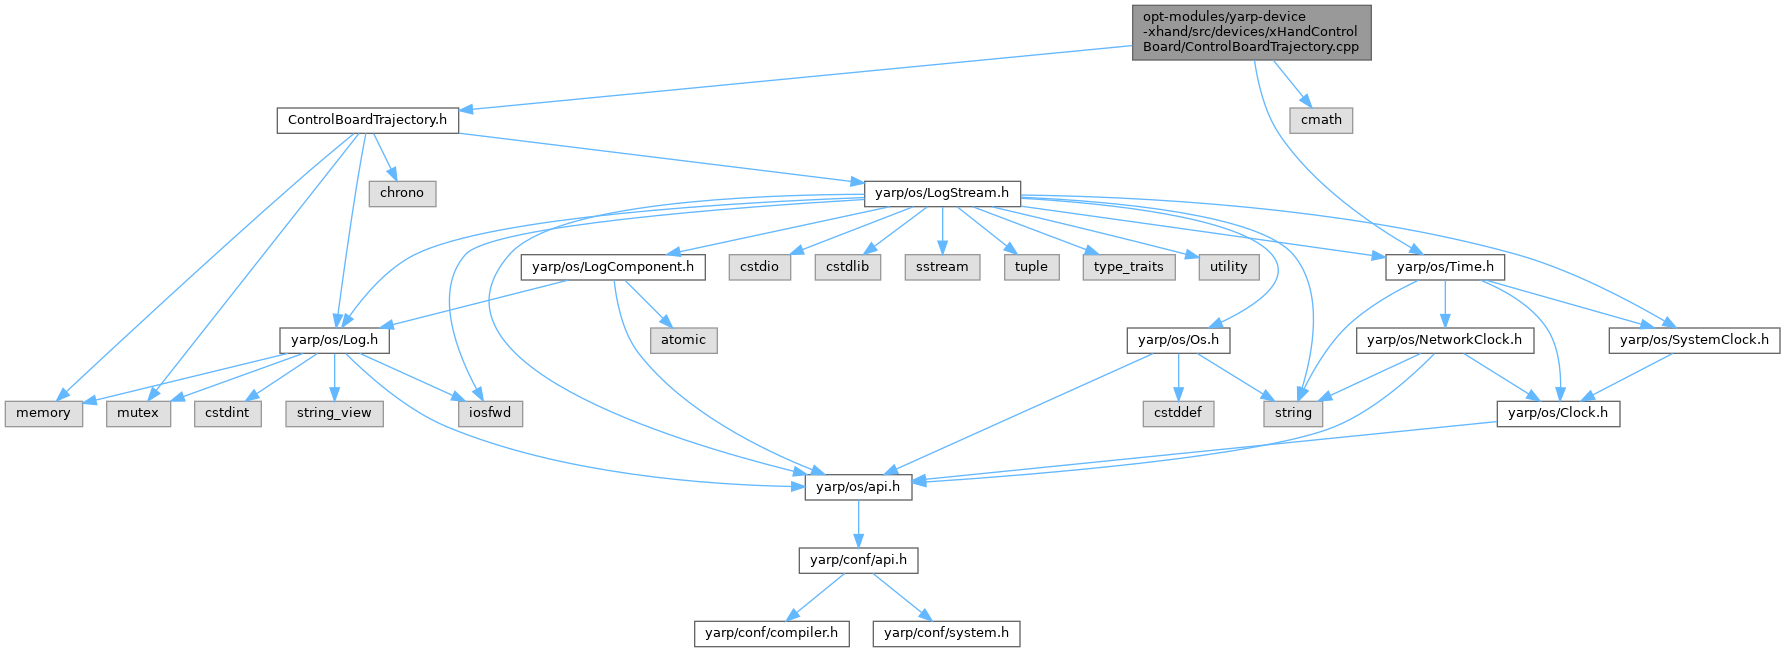
 Include dependency graph for ControlBoardTrajectory.cpp:
 1.9.8